IM Series
Attitude · IMU — 5 modules 01 · AttitudeSMT · Reference
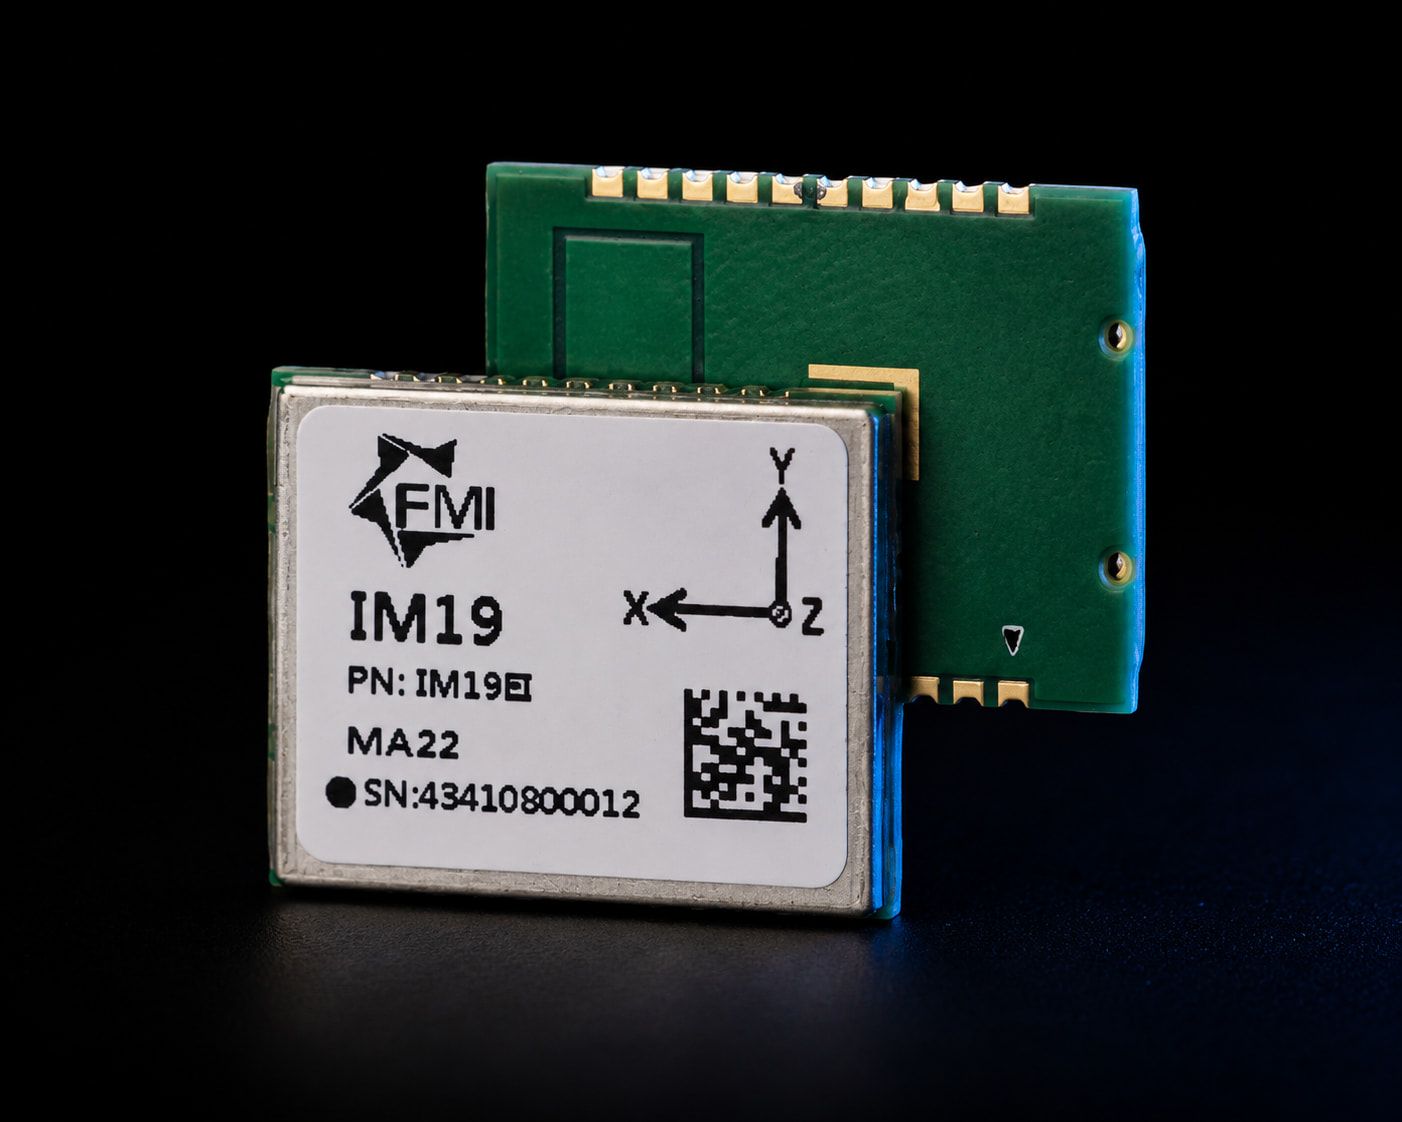
The original tilt-compensation reference
The module that effectively set the GNSS tilt-compensation bar. Over 100,000 units in active field service by 2023, integrated by 20+ surveying partners worldwide. Multi-jurisdiction patents and painless integration.
- Units shipped
- 100K+
- Roll/Pitch dyn
- 0.05° 2σ
- Patents
- WW
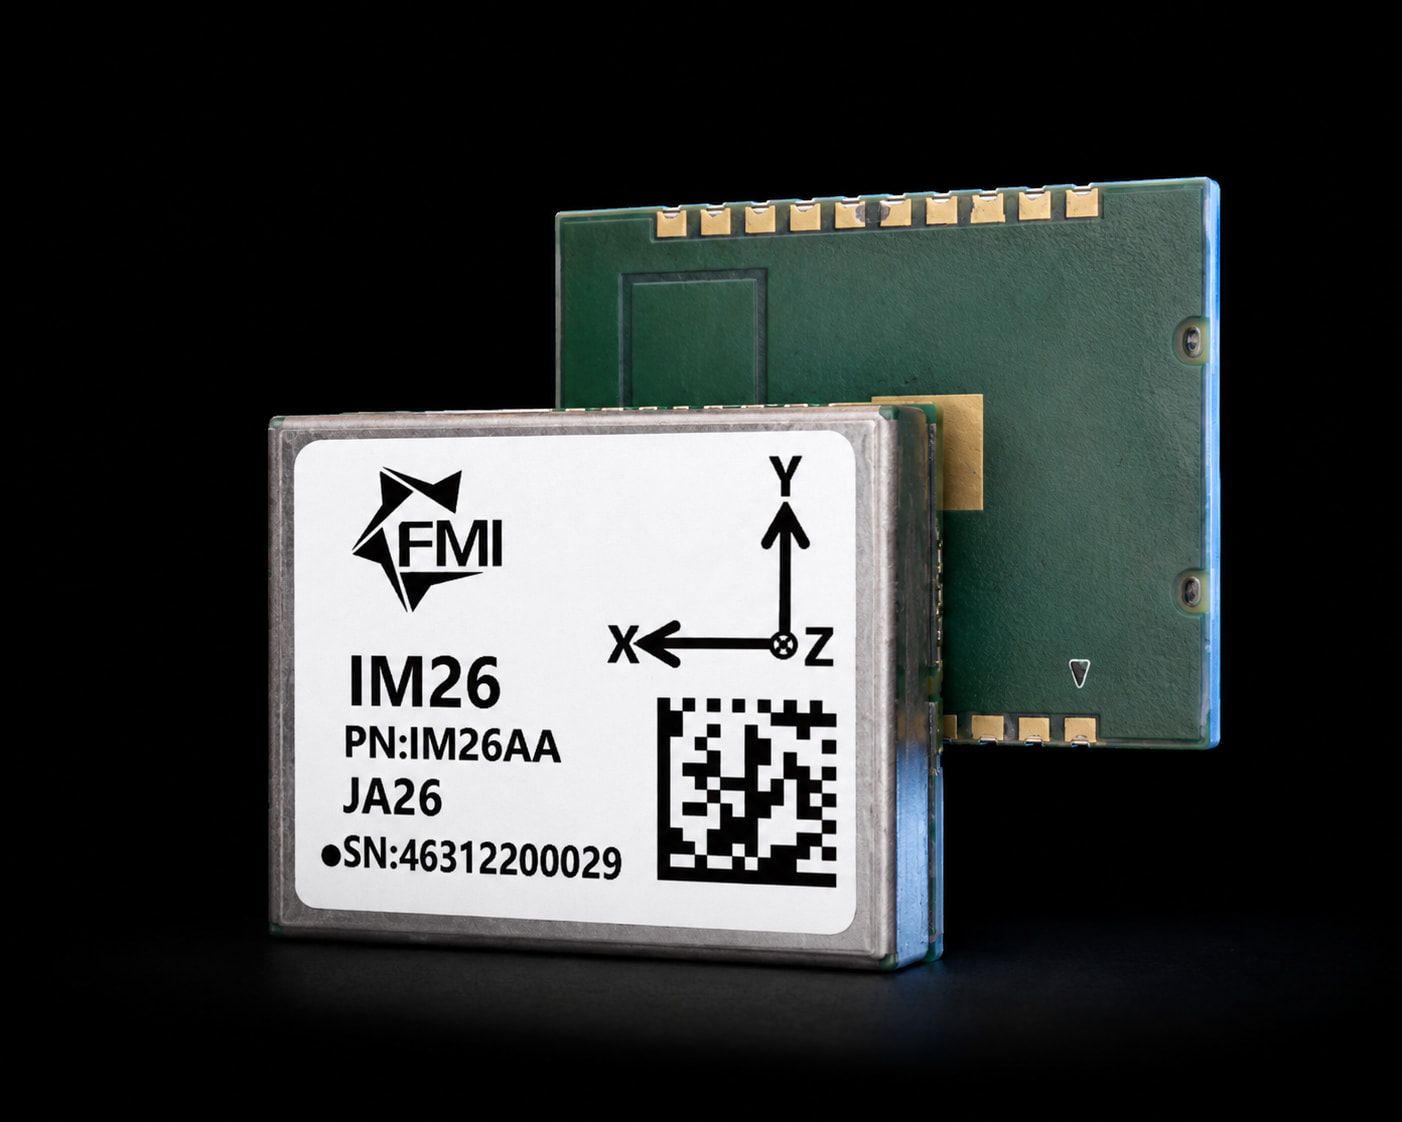
02 · AttitudeSMT · GNSS-fused
Newest SMT IMU — GNSS RTK fused
Wide-temperature-compensated IMU that fuses MEMS gyro / accelerometer with GNSS RTK to deliver roll & pitch within 0.02° (2σ). Protected under US and Chinese patents. Built for machine control, robotics, drones, tilt surveys, AHRS, and dead reckoning.
- Roll/Pitch
- 0.02° 2σ
- Gyro BI
- 1 °/h
- Form
- SMT
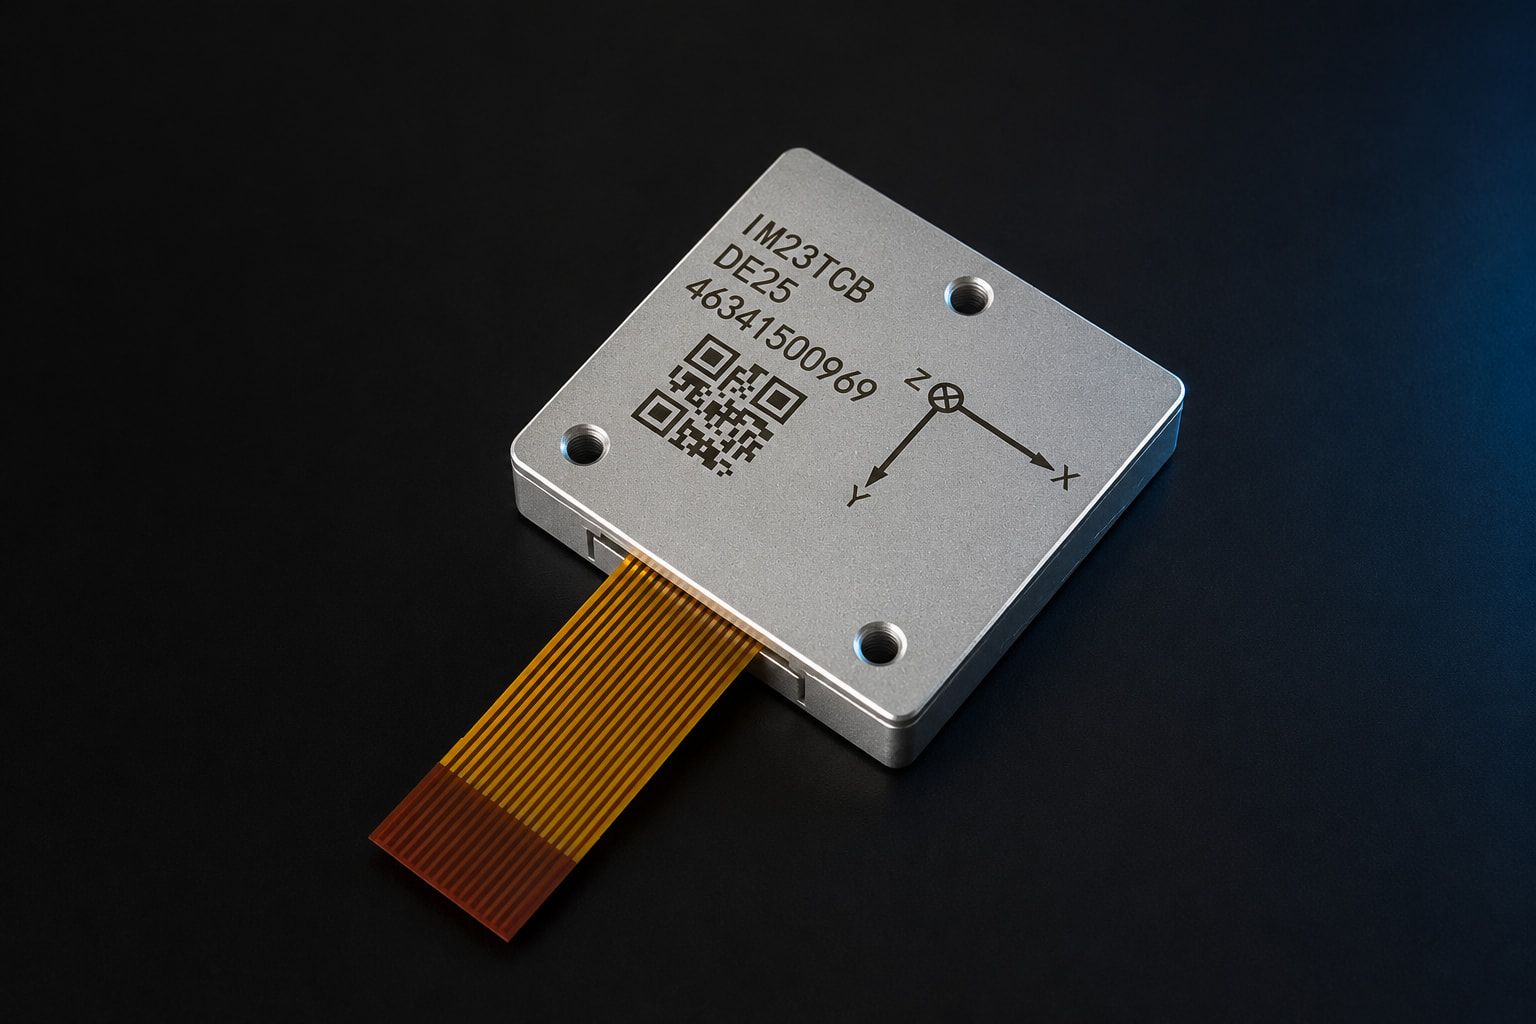
03 · AttitudeIndustrial · Hardened
Screw-mount IMU for harsh environments
Mechanically hardened 25 × 25 × 5.9 mm successor to IM19, built for the harshest industrial environments. Factory-calibrated temperature compensation across the full operating range, dynamic pitch & roll to 0.01° (2σ), gyro bias instability of 0.8 °/h, and 1000 Hz configurable output.
- Roll/Pitch dyn
- 0.01° 2σ
- Gyro BI
- 0.8 °/h
- Height
- 5.9 mm
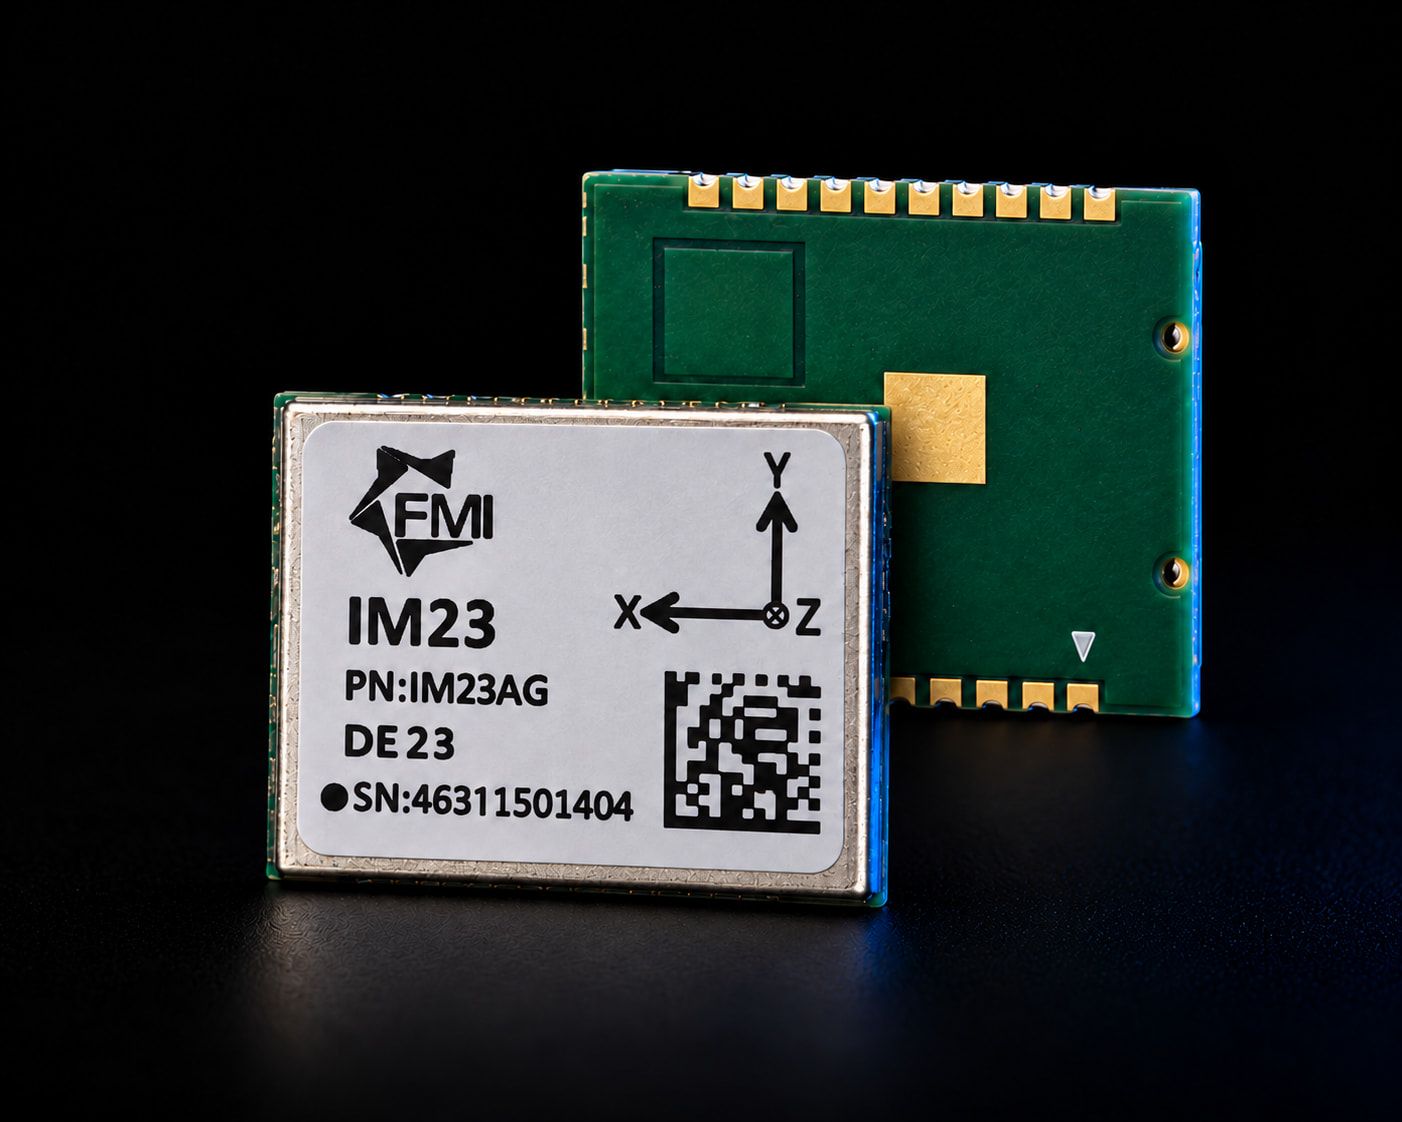
04 · AttitudeSMT · Precision agriculture
Tilt-compensation IMU for ag & auto-steering
SMT MEMS IMU fused with GNSS RTK, engineered for tilt RTK surveys, agricultural machine automation, and dead reckoning. Delivers roll & pitch to ±0.05°, heading to ±0.5°, and 1 cm tilt-survey accuracy at up to 30° pole tilt — with 1-second initialization. Auto-steering yaw accuracy 0.5° (95%). Patents in US and China.
- Roll/Pitch
- 0.05°
- Tilt survey
- 1 cm @ 30°
- Ag yaw
- 0.5° (95%)
05 · AttitudeAHRS · No GNSS
Nine-axis attitude and heading — no GNSS aiding
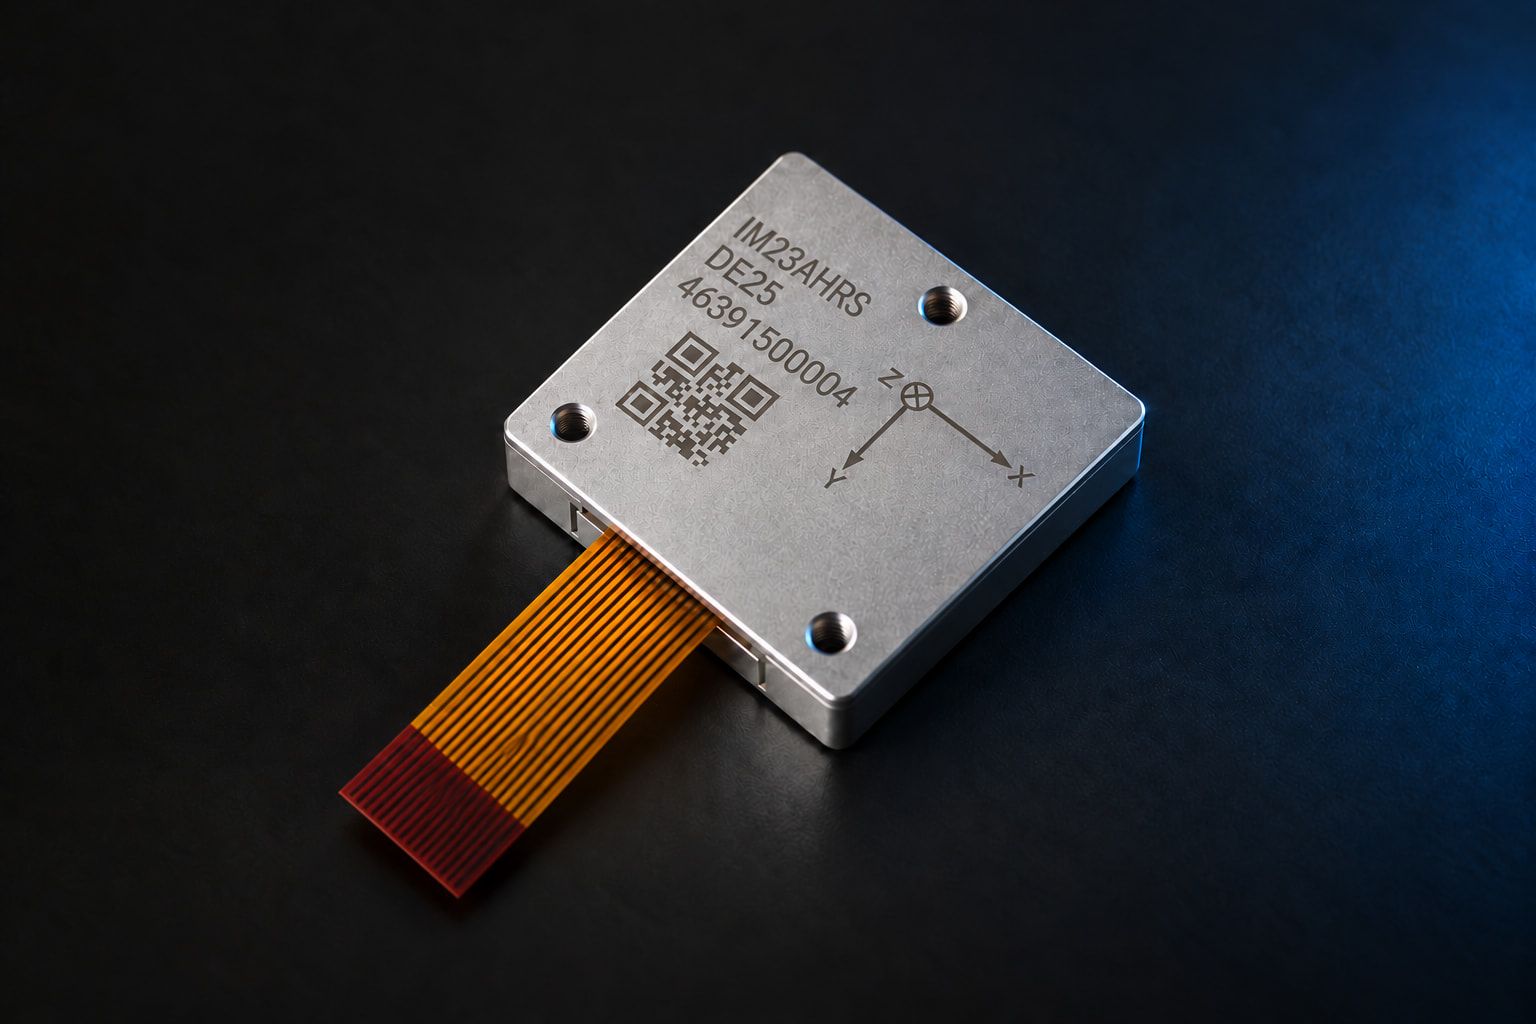
Nine-axis attitude and heading reference — the AHRS-configured IM23. Derives roll, pitch, and magnetic heading from its own gyro, accelerometer, and magnetometer, with no GNSS or RTK aiding: 0.05° static roll/pitch, 0.5° magnetic heading, output up to 1000 Hz. Built for robotics, AGVs, gimbal and platform stabilization, and antenna pointing.
- Roll/Pitch
- 0.05° static
- Heading
- 0.5° magnetic
- Output
- 1000 Hz
PM Series
GNSS · Multi-band — 2 modules 06 · GNSSHeading
World lowest-power GNSS RTK + heading
The world's lowest-power GNSS RTK and heading module with an integrated 6-axis IMU — under 100 mW at full performance, not idle. On-chip RTK, dual-antenna heading, and sensor fusion that holds up in GNSS-denied environments.
- Power
- <100 mW
- 3D
- H/R/P
07 · GNSSMulti-band
RTK across five constellations · under 50 mW
Tracks BDS, GPS, GALILEO, GLONASS and QZSS for continuous fixes through changing sky conditions. Under 50 mW, high cost-performance — well suited to wearable positioning and small UAVs.
- Power
- <50 mW
- Constellations
- 5
- Class
- RTK
VM Series
Vision · Imaging — 2 modules 08 · VisionStakeout
Visual guidance for the pole tip
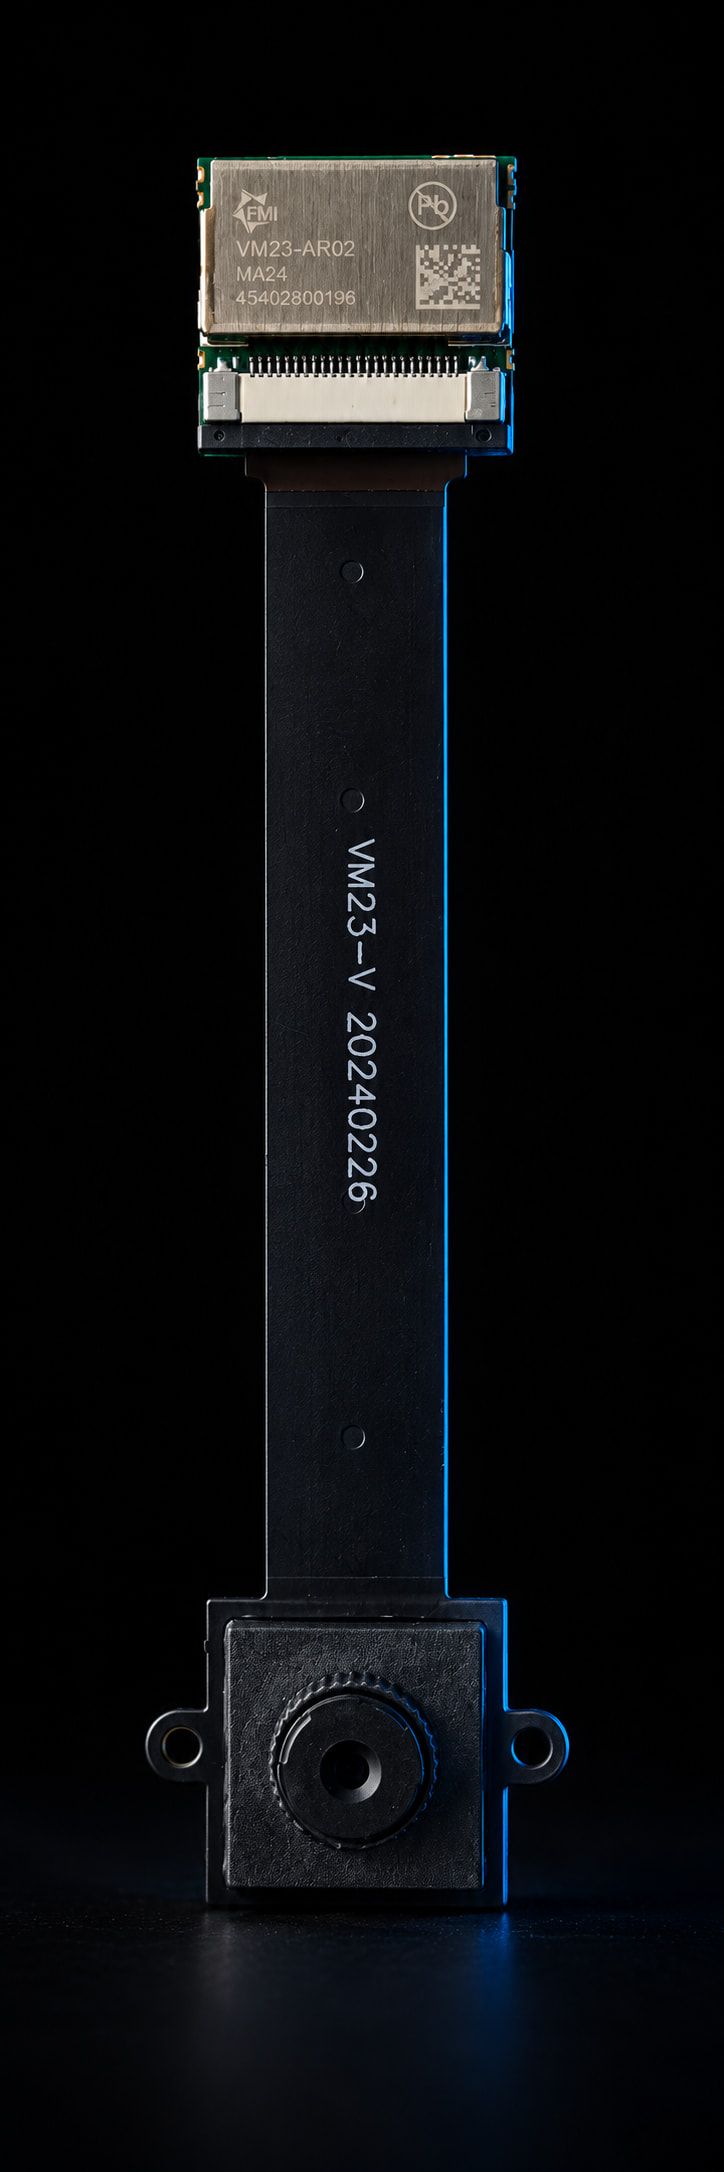
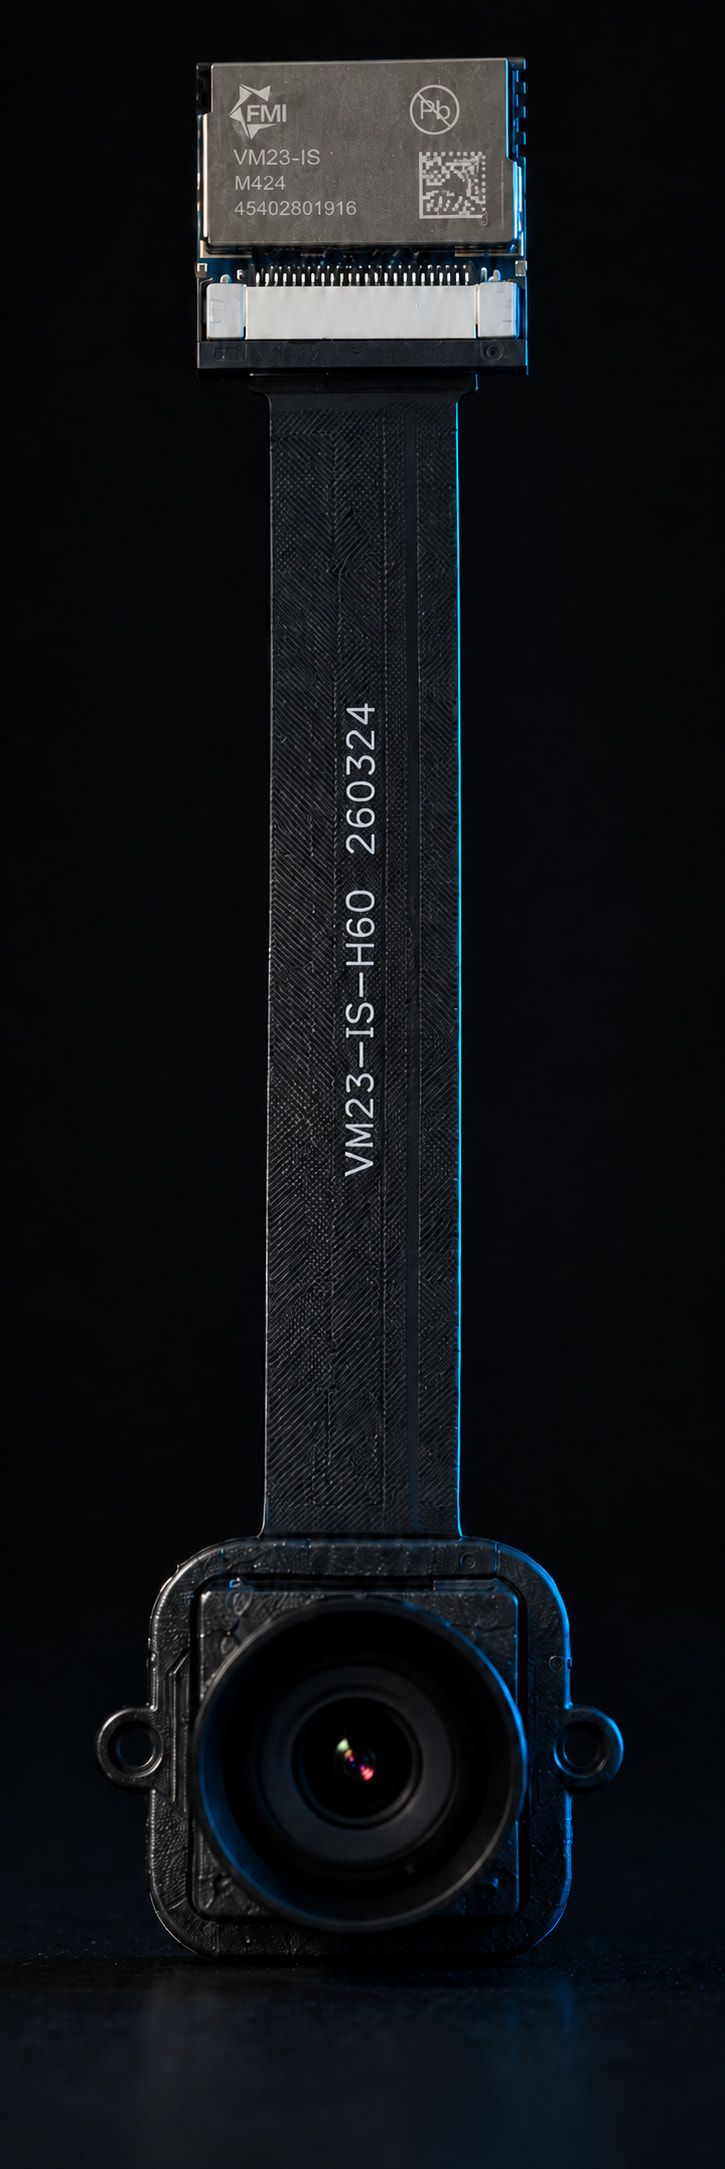
Compact assembly that augments GNSS RTK with vision to make stakeout faster and more accurate. The system shows the surveyor exactly where the tip needs to land.
- Use
- Stakeout
- Form
- Compact
09 · VisionImaging survey
Survey points on images at a distance
Vision-assisted module assembly that lets GNSS RTK survey points of interest on images at a distance. Paired with FEYMAN's IM19 or IM23 tilt module, imaging surveys reach about 2–4 cm horizontal accuracy (95%) at a 10 m target distance.
- Use
- Imaging survey
- Accuracy
- 2~4 cm @ 10 m
- Lenses
- 6 / 4.35 / 3.37 mm
RM Series
Ranging · Time-of-Flight (ToF) — 1 module 10 · RangingTime-of-Flight · Entry-level
Time-of-flight ranging, 3 – 10 m
Entry-level Time-of-Flight (ToF) distance module measuring 3 to 10 meters with millimeter-class resolution. Hardware-level time sync with other FMI modules (IM, PM, VM and MC series) over a shared PPS line — so range data drops onto the same timebase as your IMU, GNSS, and vision streams.
- Range
- 3 – 10 m
- Sync
- PPS · FMI bus
- Class
- Entry
MC Series
Machine Control (MCS) · Sealed AHRS — 1 module 11 · IndustrialSealed AHRS
Dynamic tilt & AHRS for the field
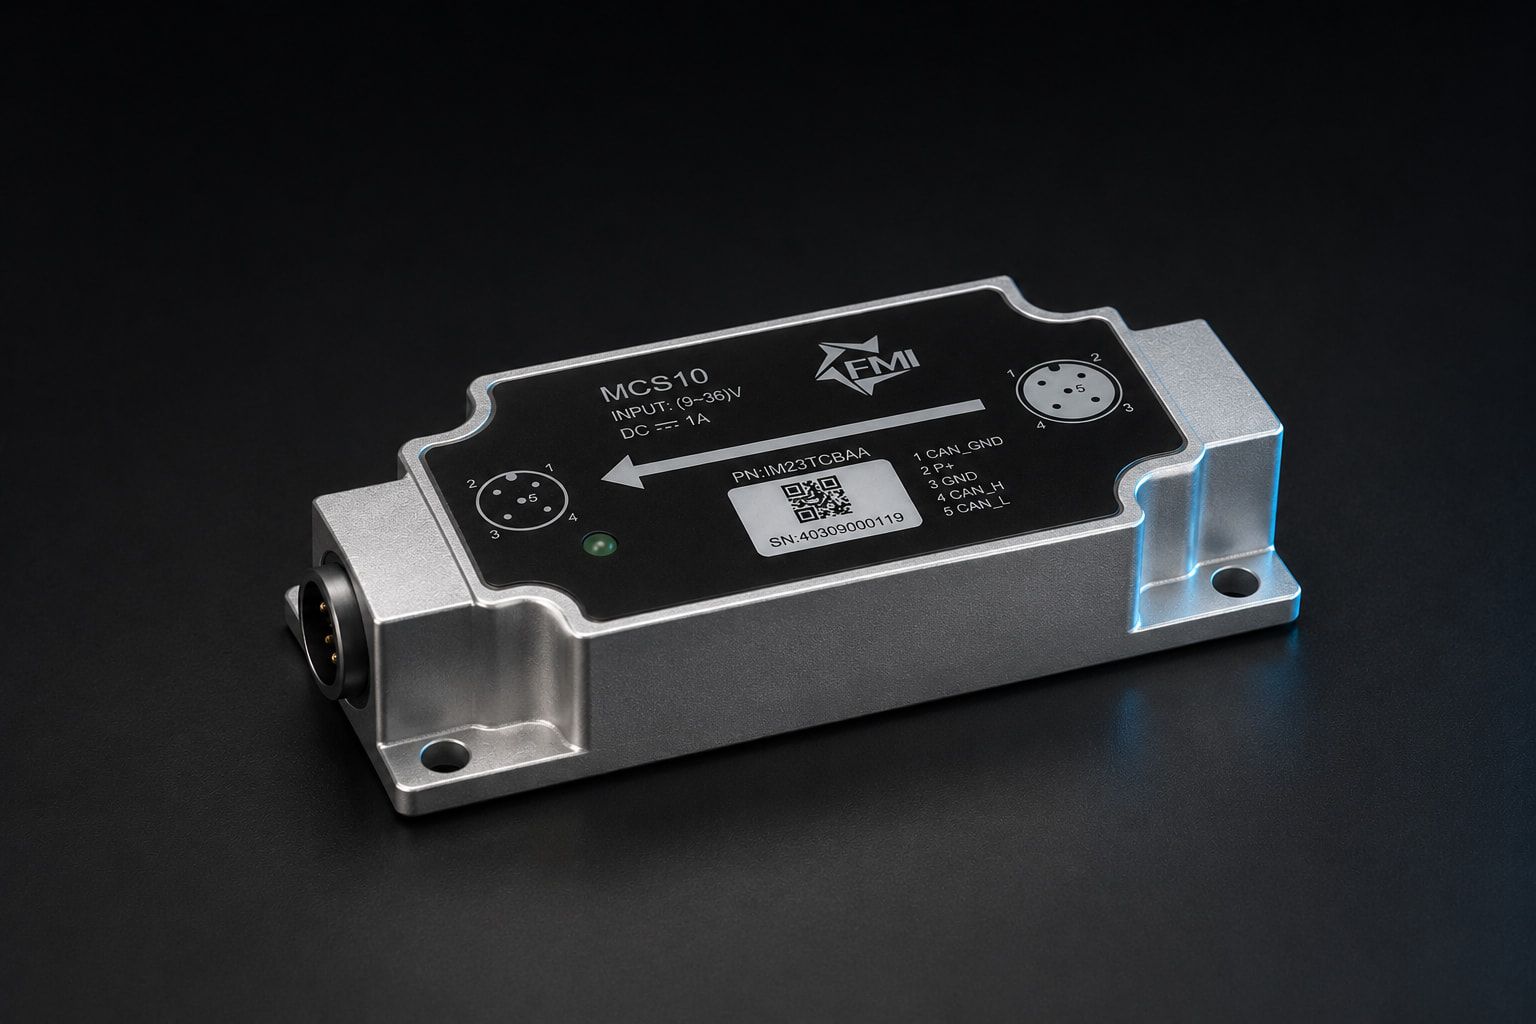
Wide-temperature calibrated dynamic tilt and attitude reference system with 9-DoF sensing, magnetometer-aided heading without GNSS, and CANopen / J1939 over dual M12 connectors. Built for construction machinery, robotics, and machine control.
- Tilt
- 0.05° static
- Rate
- 100 Hz
- IP
- 69K